Home /reference/videos

Cross product introduction

These are notes from Cross product introduction | Vectors and spaces | Linear Algebra | Khan Academy by Khan Academy.

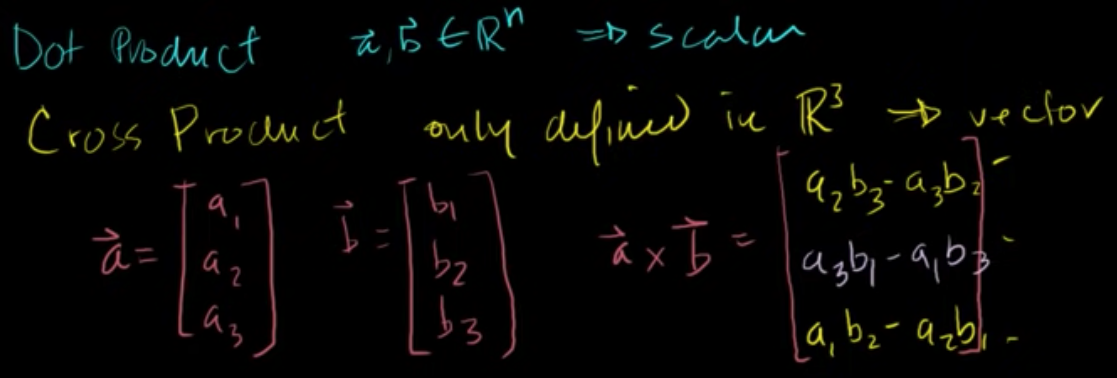
The Cross Product is much more limited than Dot Product. Where the dot product is defined in any dimension ( RNR_N ), the cross product is only defined in 3d ( R3R_{3} ).

The dot product returns a scalar; the cross product a Vector.

Definition of the dot product:

a⃗=[a1a2a3],b⃗=[b1b2b3]\vec{a} = \begin{bmatrix}a_1 \\ a_2 \\ a_3\end{bmatrix}, \vec{b} = \begin{bmatrix}b_1 \\ b_2 \\ b_3\end{bmatrix}

a⃗×b⃗=[a2⋅b3−a3⋅b2a3⋅b1−a1⋅b3a1⋅b2−a2⋅b1]\vec{a} \times \vec{b} = \begin{bmatrix} a_2 \cdot b_3 - a_3 \cdot b_2 \\ a_3 \cdot b_1 - a_1 \cdot b_3 \\ a_1 \cdot b_2 - a_2 \cdot b_1 \end{bmatrix}

  • For first row in the returned vector, you ignore the top row and take a2⋅b3−a3⋅b2a_2 \cdot b_3 - a_3 \cdot b_2
  • For the 2nd row in the returned vector, you ignore the middle row of the vectors and take a similar product to the first; however, this time, you are doing it the opposite way around: a3⋅b1−a1⋅b3a_3 \cdot b_1 - a_1 \cdot b_3
  • For the 3rd row, you ignore the last row of input and make the same operation as the first row of the top 2 rows of input: a1⋅b2−a2⋅b1a_1 \cdot b_2 - a_2 \cdot b_1.

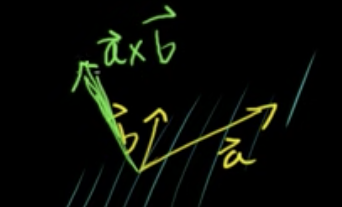
The vector that's returned is orthogonal to both a⃗\vec{a} and b⃗\vec{b}.

Orthogonal vector example

Note that two vectors are orthogonal to those vectors. To find which direction it points in, you use the right-hand rule: take your right hand and put your index finger in the direction of a⃗\vec{a} and your middle finger in the direction of b⃗\vec{b}, where your thumb is pointing in the direction of the returned vector.

What does orthogonal mean in this context? It means if a⃗⋅b⃗=0\vec{a} \cdot \vec{b} = 0, the difference between orthogonal vectors and perpendicular vectors is orthogonal could also apply to 0 vectors.

You can prove it works by taking the dot product with one of the input vectors and the output vector:
[a2⋅b3−a3⋅b2a3⋅b1−a1⋅b3a1⋅b2−a2⋅b1]⋅[a1a2a3]\begin{bmatrix} a_2 \cdot b_3 - a_3 \cdot b_2 \\ a_3 \cdot b_1 - a_1 \cdot b_3 \\ a_1 \cdot b_2 - a_2 \cdot b_1 \end{bmatrix} \cdot \begin{bmatrix}a_1 \\ a_2 \\ a_3\end{bmatrix}

=a1a2b3−a1a3b2+a2a3b1−a2a1b3+a3a1b2−a3a2b1= a_1 a_2 b_3 - a_1 a_3 b_2 + a_2 a_3 b_1 - a_2 a_1 b_3 + a_3 a_1 b_2 - a_3 a_2 b_1

=a1a2b3−a1a3b2+a2a3b1−a2a1b3+a3a1b2−a3a2b1= \mathbf{a_1 a_2 b_3} - a_1 a_3 b_2 + a_2 a_3 b_1 \mathbf{- a_2 a_1 b_3} + a_3 a_1 b_2 - a_3 a_2 b_1

=−a1a3b2+a2a3b1+a3a1b2−a3a2b1= \mathbf{-a_1 a_3 b_2} + a_2 a_3 b_1 + \mathbf{a_3 a_1 b_2} - a_3 a_2 b_1

=a2a3b1−a3a2b1= \mathbf{a_2 a_3 b_1} \mathbf{- a_3 a_2 b_1}

=0= 0

Maths/LinearAlgebra/CrossProduct